| Model | VSM0613 |
| Brand | Vic-Tech |
| Motor type | 6 mm micro stepper motor |
| Driving Voltage | 3.3 v |
| Current / phase | 0.2A |
| Minimum order quantity | 1 unit |
| Certification | Rohs |
| OEM & ODM Service | Available |

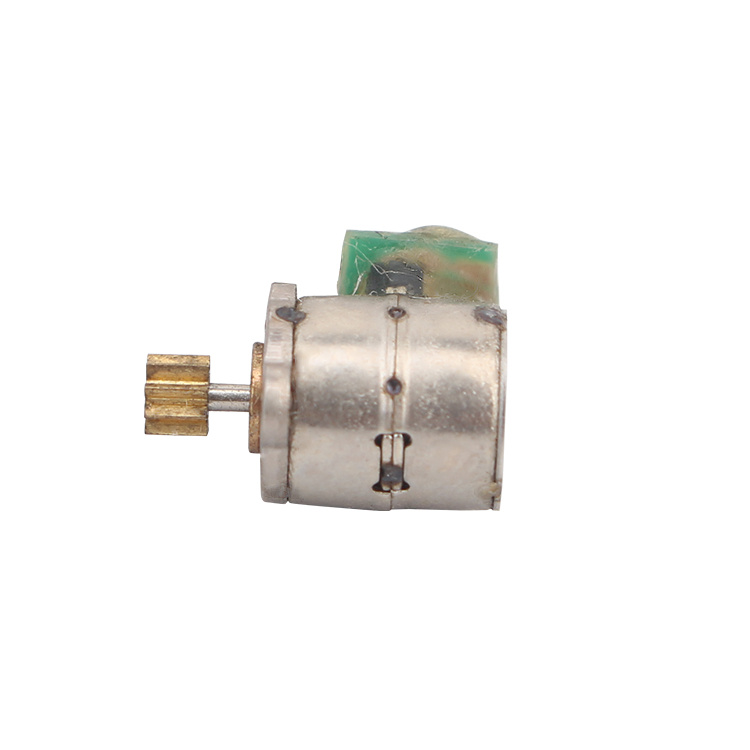
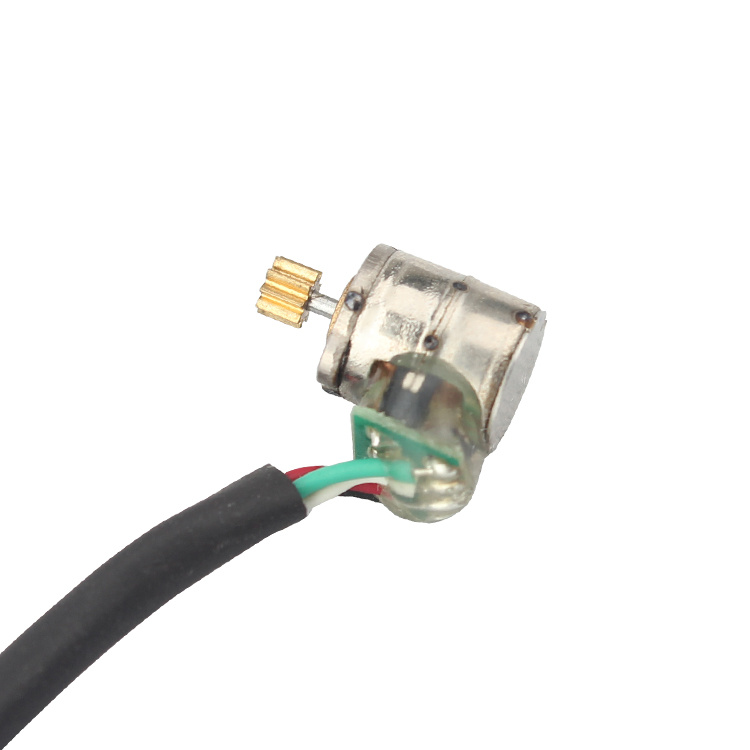
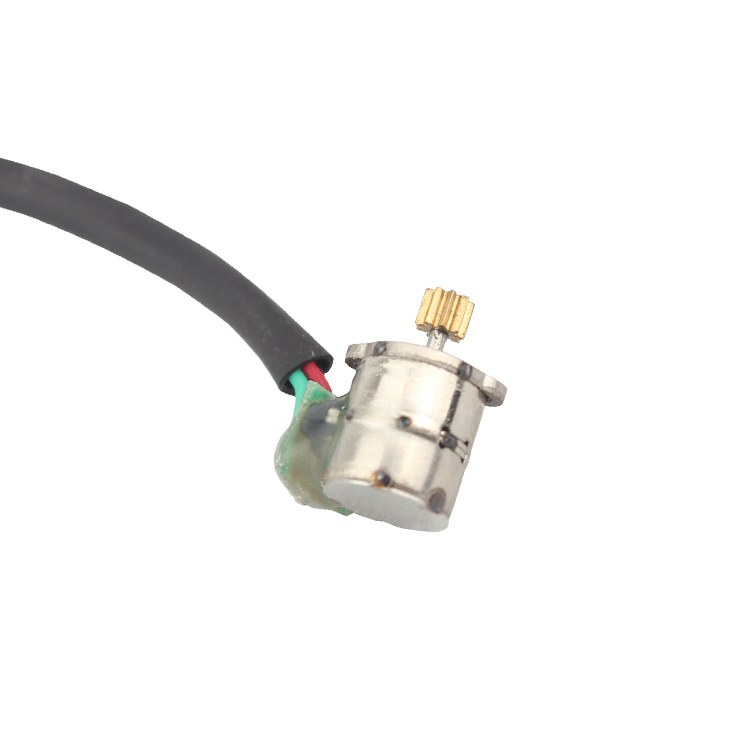
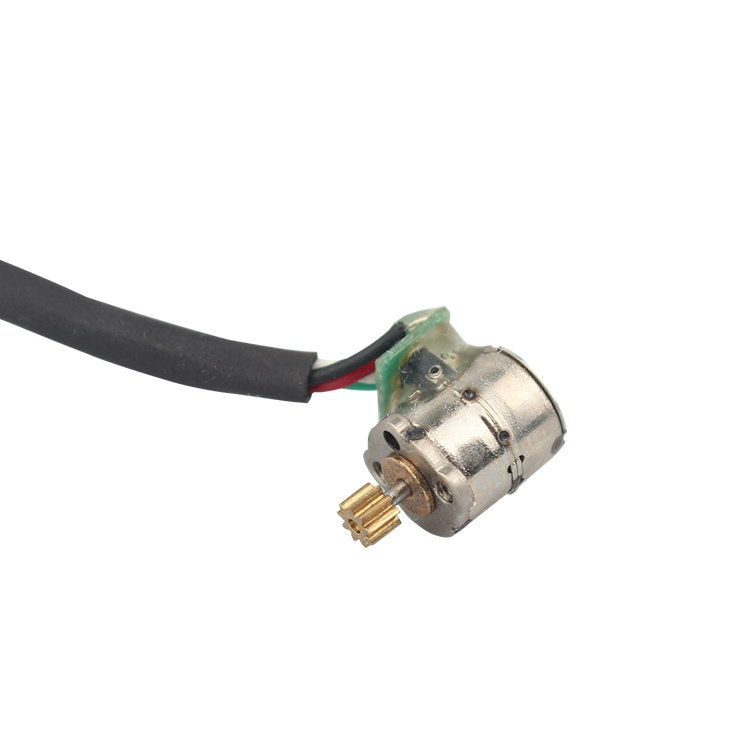
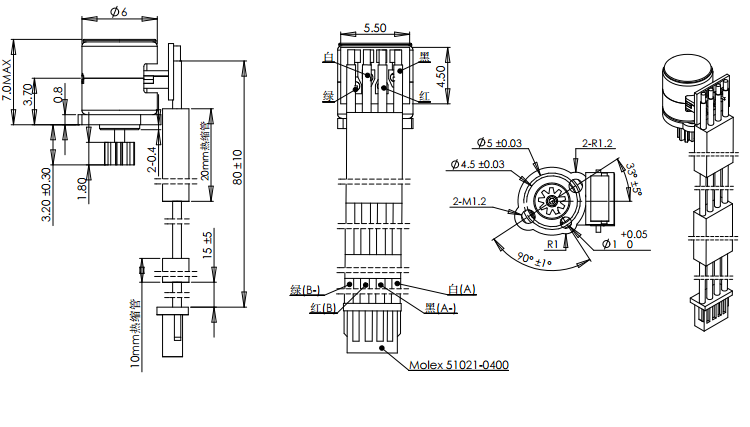
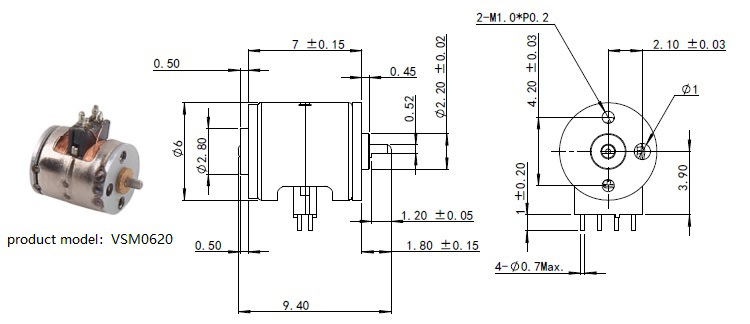
VSM0613 is a micro stepping motor. The motor diameter is 6 mm, the height is 7 mm, the diameter of the output shaft is 1 mm, and the height of the conventional output shaft is 3.1 mm. The length of the output shaft can be customized according to the customer’s installation needs. The motor output shaft is equipped with a conventional gear with a module of 0.2, a number of teeth of 9, and a gear thickness of 1.8 mm. The gear can also be customized according to the customer’s requirements
Positionierung erfolgt über die Anzahl der vom Motor zurückgelegten Schritte.
Automatisierung und Robotik: Die Drehgeschwindigkeit wird durch die Frequenz der Impulse bestimmt.
Der Motor bleibt im Stillstand, wobei dennoch ein Haltemoment vorhanden ist.
| Product name | 6 mm micro stepper motor |
| Model | Vsm0613 |
| Max. Starting frequency | 1300 pps min. (at 3.3 v dc) |
| Max. Slewing frequency | 2500 pps min. (at 3.3 v dc) |
| Pull in torque | 0.8gf-cm min. (at 500 pps , 3.3v dc) |
| Pull out torque | 1.0gf-cm min. (at 500 pps , 3.3v dc) |
| Insulation class | Class e for coils |
| Insulation strength | 3.0ma (MAX.) |
| Insulation resistence | 1 mω (dc 100 v) |
| Operating temperature range | -10~+60 ℃ |
| Oem & odm service | Available |
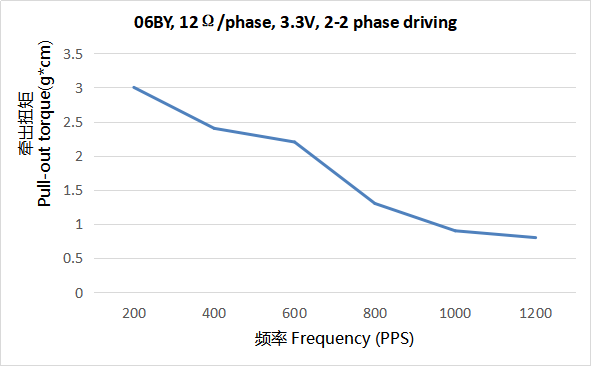
| VSM06, 12Ω 3.3V 2-2 Phase | ||||||
| Frequency (PPS) | 200 | 400 | 600 | 800 | 1000 | 1200 |
| Pull-out torque (g*cm) | 3 | 2.4 | 2.2 | 1.3 | 0.9 | 0.8 |
Motor’s diameter: We have 6mm, 8mm, 10mm, 15mm and 20 mm diameter motor
Connection method and direction:FPC,PCB
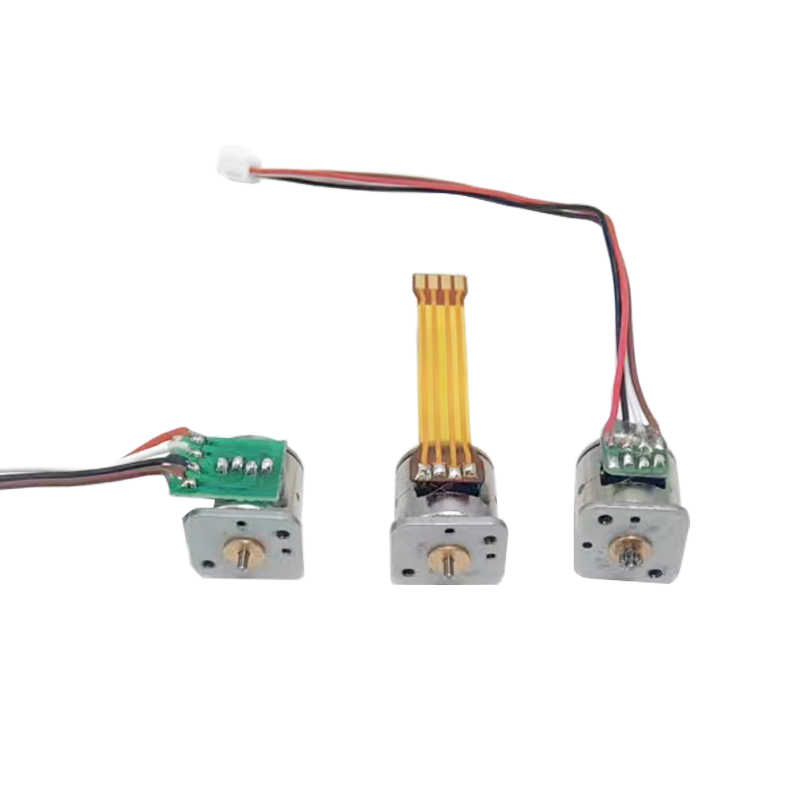
Cap:Round, square, binaural, other shapes can be customised
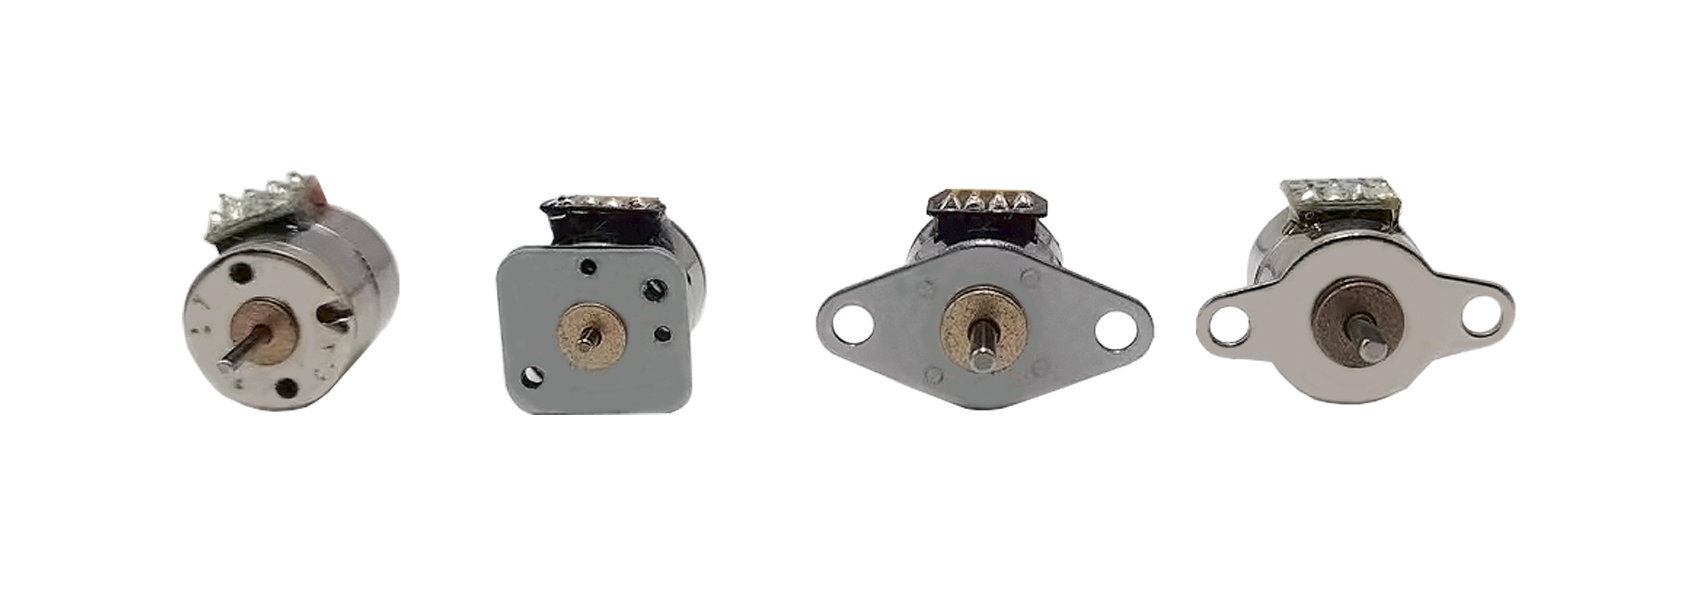
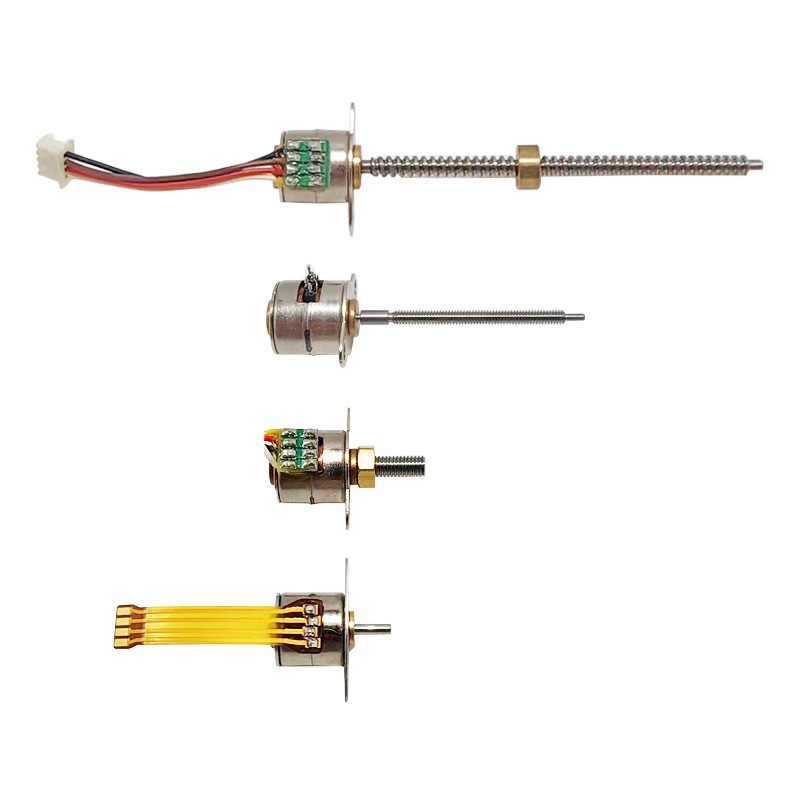
Outgoing shaft type:Round shaft, D-axis, screws
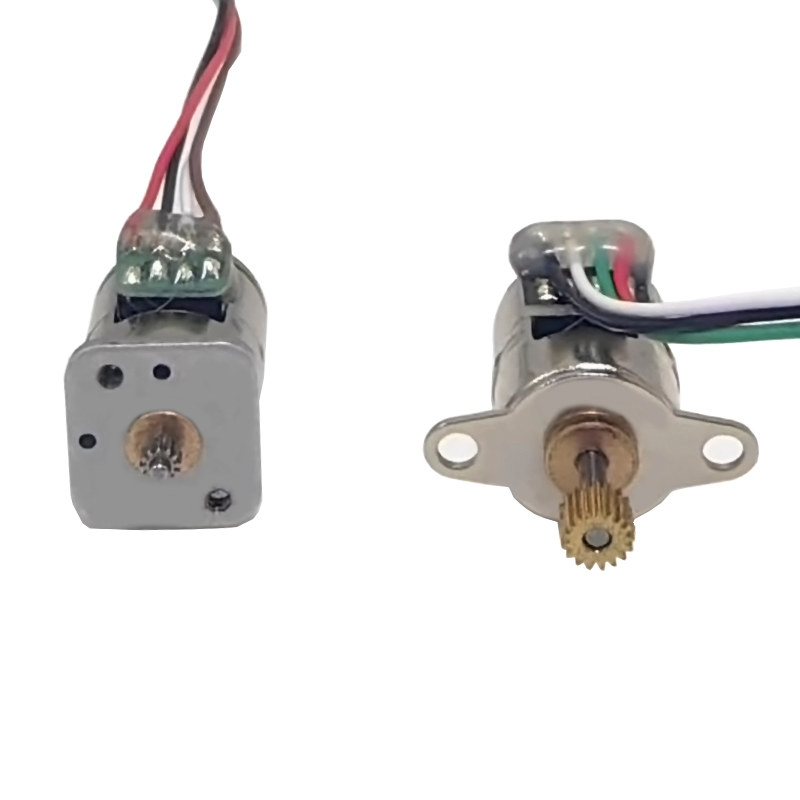
Shaft gear:Can be customised on request
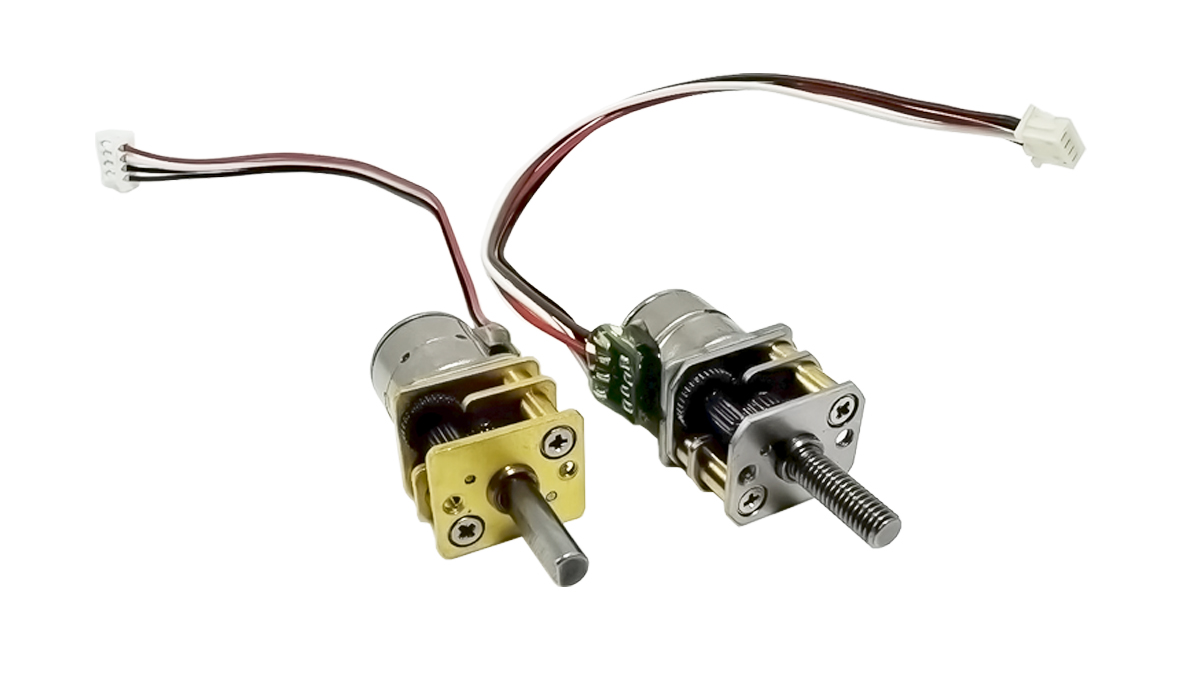
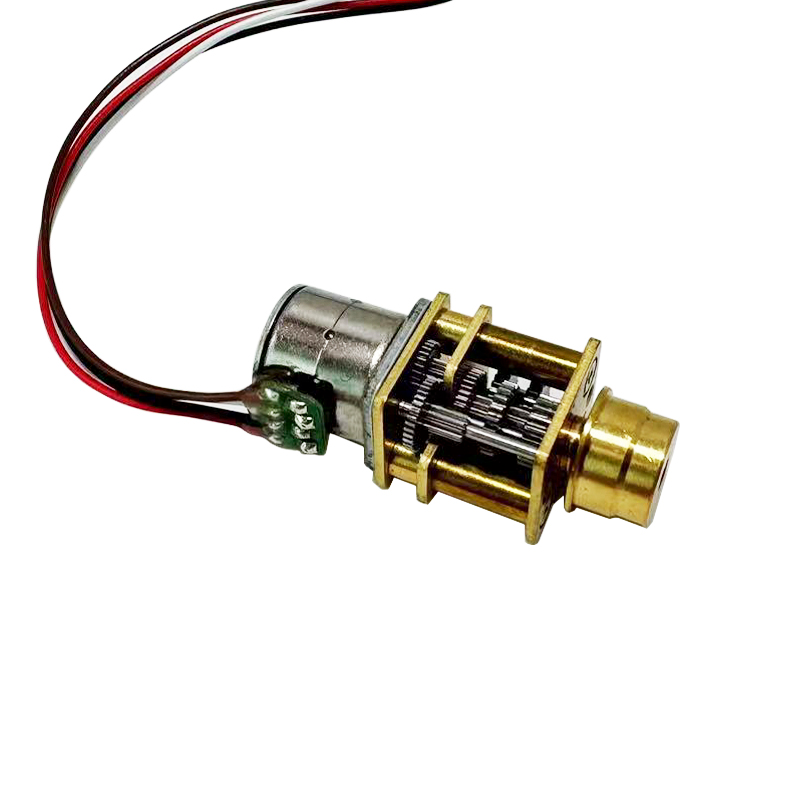
Stepper motor gearboxes:Worm gearboxes, horizontal gearboxes, 12GB gearboxes, also customised stepper motor gearboxes on request
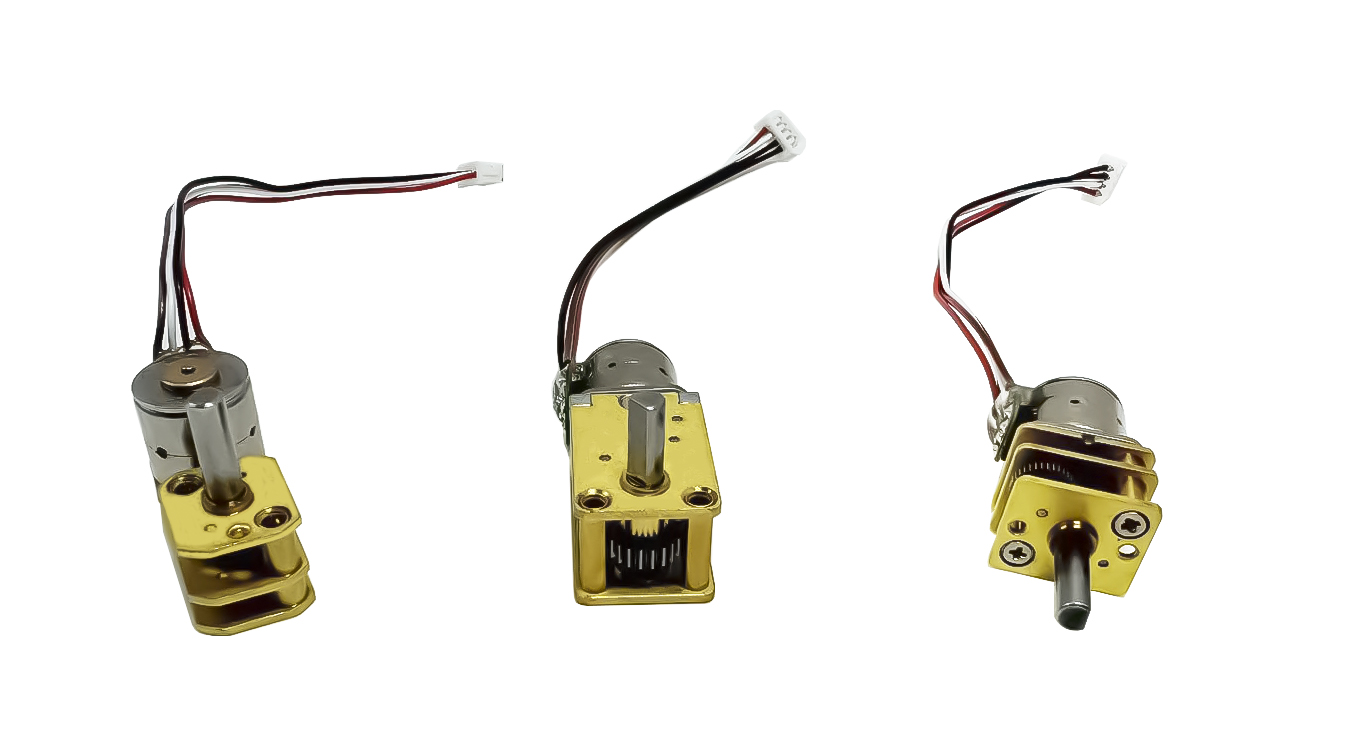
Reduction gearbox outlet shaft type: D-axis, screw
| Gear ratio | 2:1 | 5:1 | 10:1 | 15:1 | 20:1 | 30:1 | 36:1 | 50: | 63:1 | 67:1 | 89:1 | 100:1 |
| Precise ratio | 2.002 | 4.995 | 9.677 | 14.754 | 20.501 | 29.120 | 36.122 | 51.103 | 63.071 | 66.801 | 89.227 | 99.002 |
| Gear ratio | 23 | 20 | 13 | 18 | 15 | 12 | 20 | 20 | 14 | 17 | 14 | 13 |
| Gear levels | 2 | 2 | 2 | 3 | 3 | 3 | 4 | 4 | 4 | 4 | 4 | 4 |
| Efficiency | 80% | 80% | 80% | 72% | 72% | 72% | 65% | 65% | 65% | 65% | 65% | 65% |
| Input and output directions | + | + | + | – | – | – | + | + | + | + | + | + |
| Gear ratio | 120:1 | 150:1 | 172:1 | 210:1 | 250:1 | 275:1 | 298:1 | 380:1 | 420:1 | 500:1 | 600:1 | 1000:1 |
| Precise ratio | 118.922 | 150.948 | 171.883 | 210.591 | 250.111 | 274.403 | 297.924 | 387:689 | 421.296 | 506.155 | 599.394 | 986.406 |
| Gear ratio | 17 | 18 | 13 | 12(15) | 13 | 12 | 12 | 12 | 12 | 18 | 16 | 12 |
| Gear levels | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 7 | 7 | 7 |
| Efficiency | 59% | 59% | 59% | 59% | 59% | 59% | 59% | 59% | 59% | 47% | 47% | 47% |
| Input and output directions | – | – | – | – | – | – | – | – | – | – | – | – |
Geared stepper motors or micro stepper motor + dust jacket
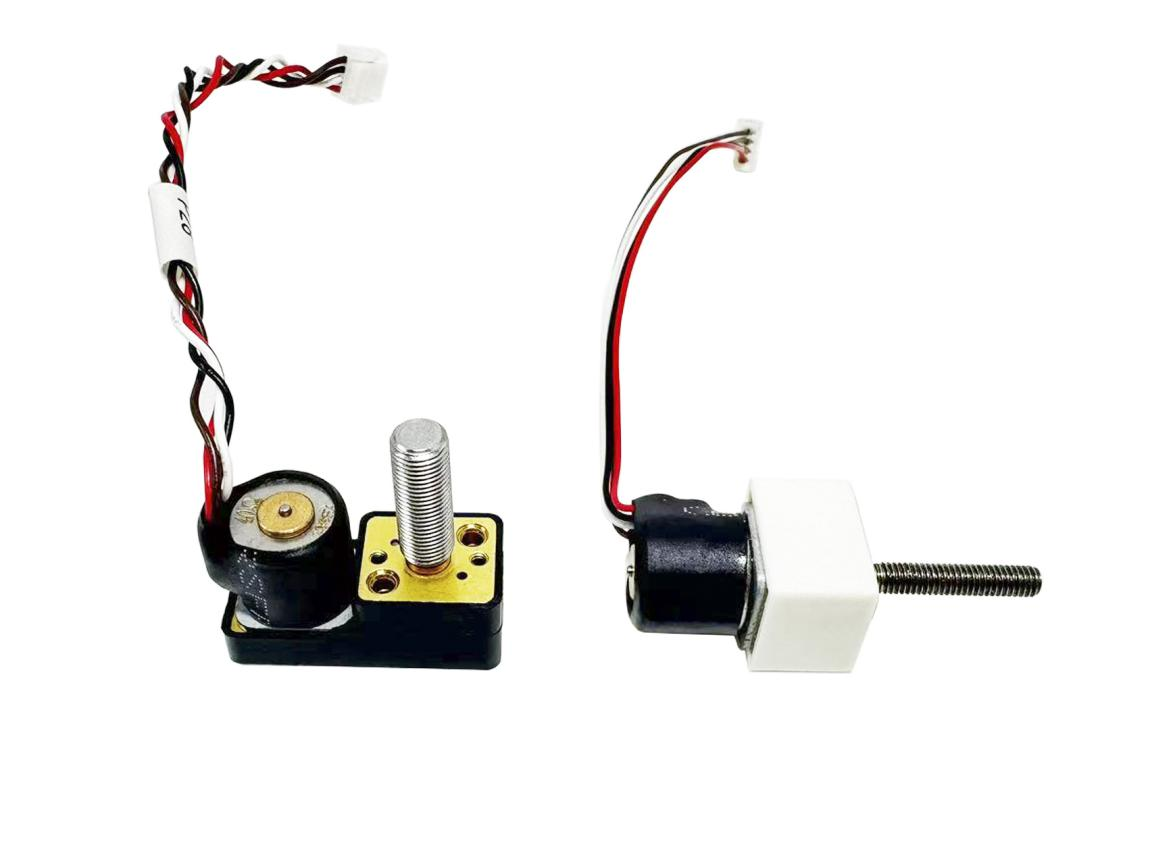
6mm micro stepper motor with gearbox and encoder
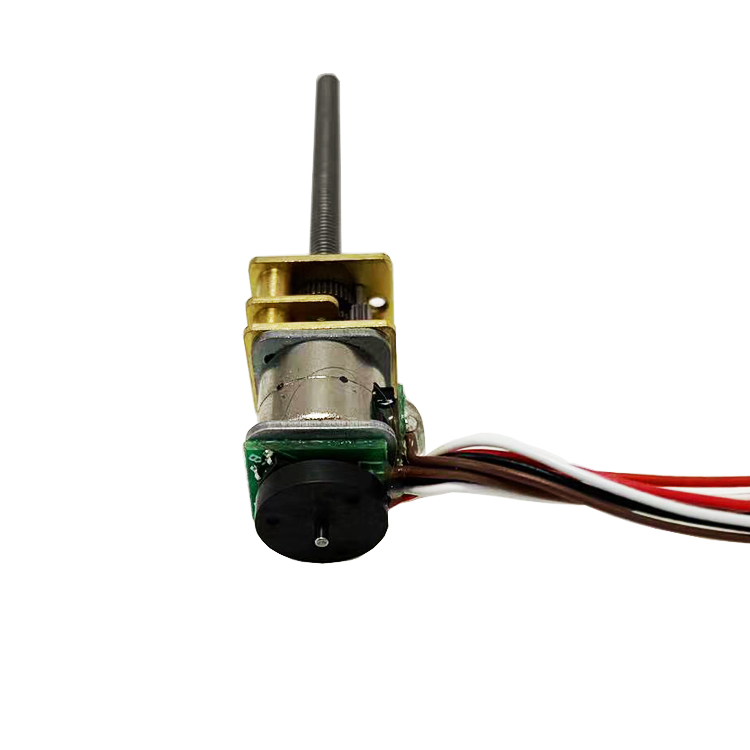
6mm micro stepper motor with resistor
Unsere Mikroschrittmotoren haben in der Regel einen Schrittwinkel von 18 Grad (Vollschrittbetrieb).
Das bedeutet, dass für eine Umdrehung 20 Schritte erforderlich sind.
Der Schrittwinkel eines Motors hängt mit der internen Konstruktion des Stators zusammen.
Die Drehzahl eines Schrittmotors wird durch die Ansteuerfrequenz bestimmt und hat nichts mit der Belastung zu tun (es sei denn, er verliert Schritte).
Aufgrund der hochpräzisen Drehzahlregelung von Schrittmotoren lässt sich mit einem treiber-gesteuerten Schrittbetrieb eine sehr genaue Positionierung und Geschwindigkeitsregelung erreichen. Aus diesem Grund sind Schrittmotoren die bevorzugte Motorenart für zahlreiche Präzisionsanwendungen in der Bewegungssteuerung.
Wir bieten Mikroschrittmotoren in verschiedenen Durchmessern an; das Drehmoment des Motors hängt von seiner Größe ab.
Hier ist die Beziehung zwischen dem Durchmesser des Motors und seinem Drehmoment (bei geeigneter Betriebsfrequenz und Nennspannung):
6 mm Motor: ca. 1 g·cm
8-mm-Motor: etwa 3 g·cm
10 mm Motor: ca. 5 g·cm
15 mm Motor: ca. 15 g·cm
20 mm Motor: ca. 40 g·cm
Die Drehzahl eines Motors wird durch die Ansteuerfrequenz bestimmt und hat nichts mit der Belastung zu tun (es sei denn, er verliert Schritte).
Aufgrund der hochpräzisen Drehzahlregelung von Schrittmotoren lässt sich mit einem treiber-gesteuerten Schrittbetrieb eine sehr genaue Positionierung und Geschwindigkeitsregelung erreichen. Aus diesem Grund sind Schrittmotoren die bevorzugte Motorenart für zahlreiche Präzisionsanwendungen in der Bewegungssteuerung.
1. High precision positioning
Da Schrittmotoren sich in präzisen, wiederholbaren Schritten bewegen, eignen sie sich besonders für Anwendungen, die eine exakte
Dieser Permanentmagnet‑Schrittmotor weist einen Durchmesser von 20 mm auf, liefert ein Drehmoment von 60 gf·cm und erreicht eine maximale Drehzahl von 3000 U/min.
2. High precision speed control
Präzise Bewegungsschritte ermöglichen zudem eine hervorragende Regelung der Rotationsgeschwindigkeit für Prozess‑
Dieser Motor kann auch mit einem Getriebe kombiniert werden; sein Schrittwinkel beträgt 18 Grad, was 20 Schritte pro Umdrehung entspricht. Durch den Einsatz eines Getriebes lässt sich die Auflösung des Drehwinkels auf 0,05 bis 6 Grad verbessern, sodass er für vielfältige Anwendungen geeignet ist, insbesondere für präzise Steuerung der Rotationsposition.
3. Pause and holding function
Durch die Ansteuerung des Antriebs verfügt der Motor über eine Blockierfunktion (es fließt Strom durch die Motorwicklungen, doch
Der Widerstand der Motorwicklung beträgt 9 Ω pro Phase, und der Motor ist für eine niedrige Versorgungsspannung (ca. 5 V Gleichstrom) ausgelegt. Sollte der Kunde den Motor mit höherer Spannung betreiben wollen, können wir den Wicklungswiderstand entsprechend anpassen.
4. Long service life & low electromagnetic interference
Der Schrittmotor besitzt keine Bürsten und muss daher nicht wie ein bürstenbehafteter
Gleichstrommotor durch Bürsten kommutiert werden. Dadurch entfällt die Reibung der Bürsten, was die Lebensdauer erhöht, elektrische Funkenbildung vermeidet und elektromagnetische Störungen verringert.